SPRING 2024
Spring 2024 represented a critical design phase for POLARIS.
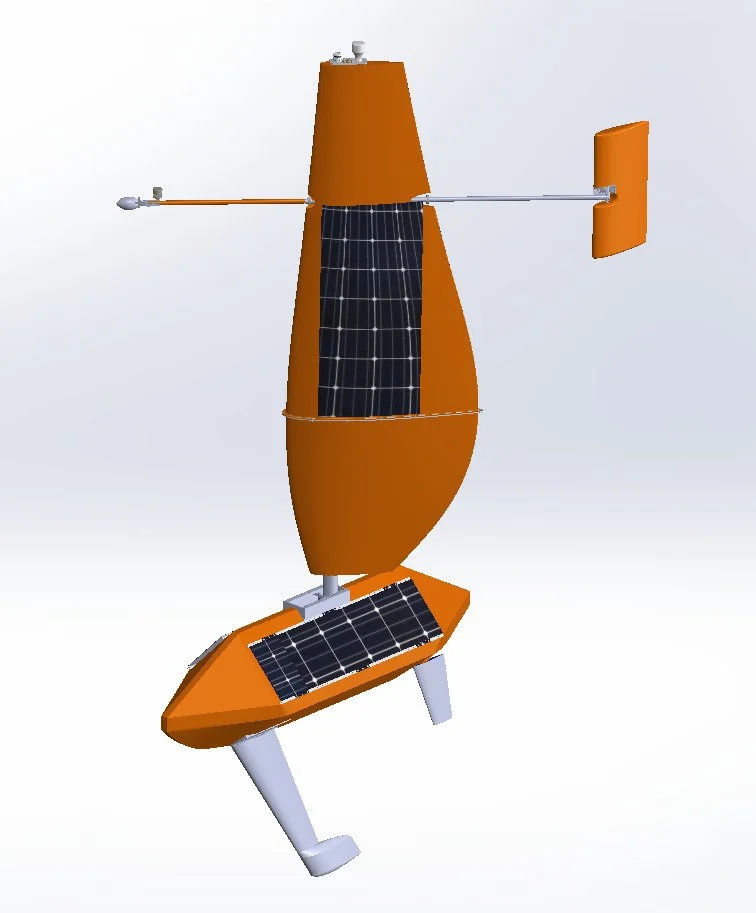
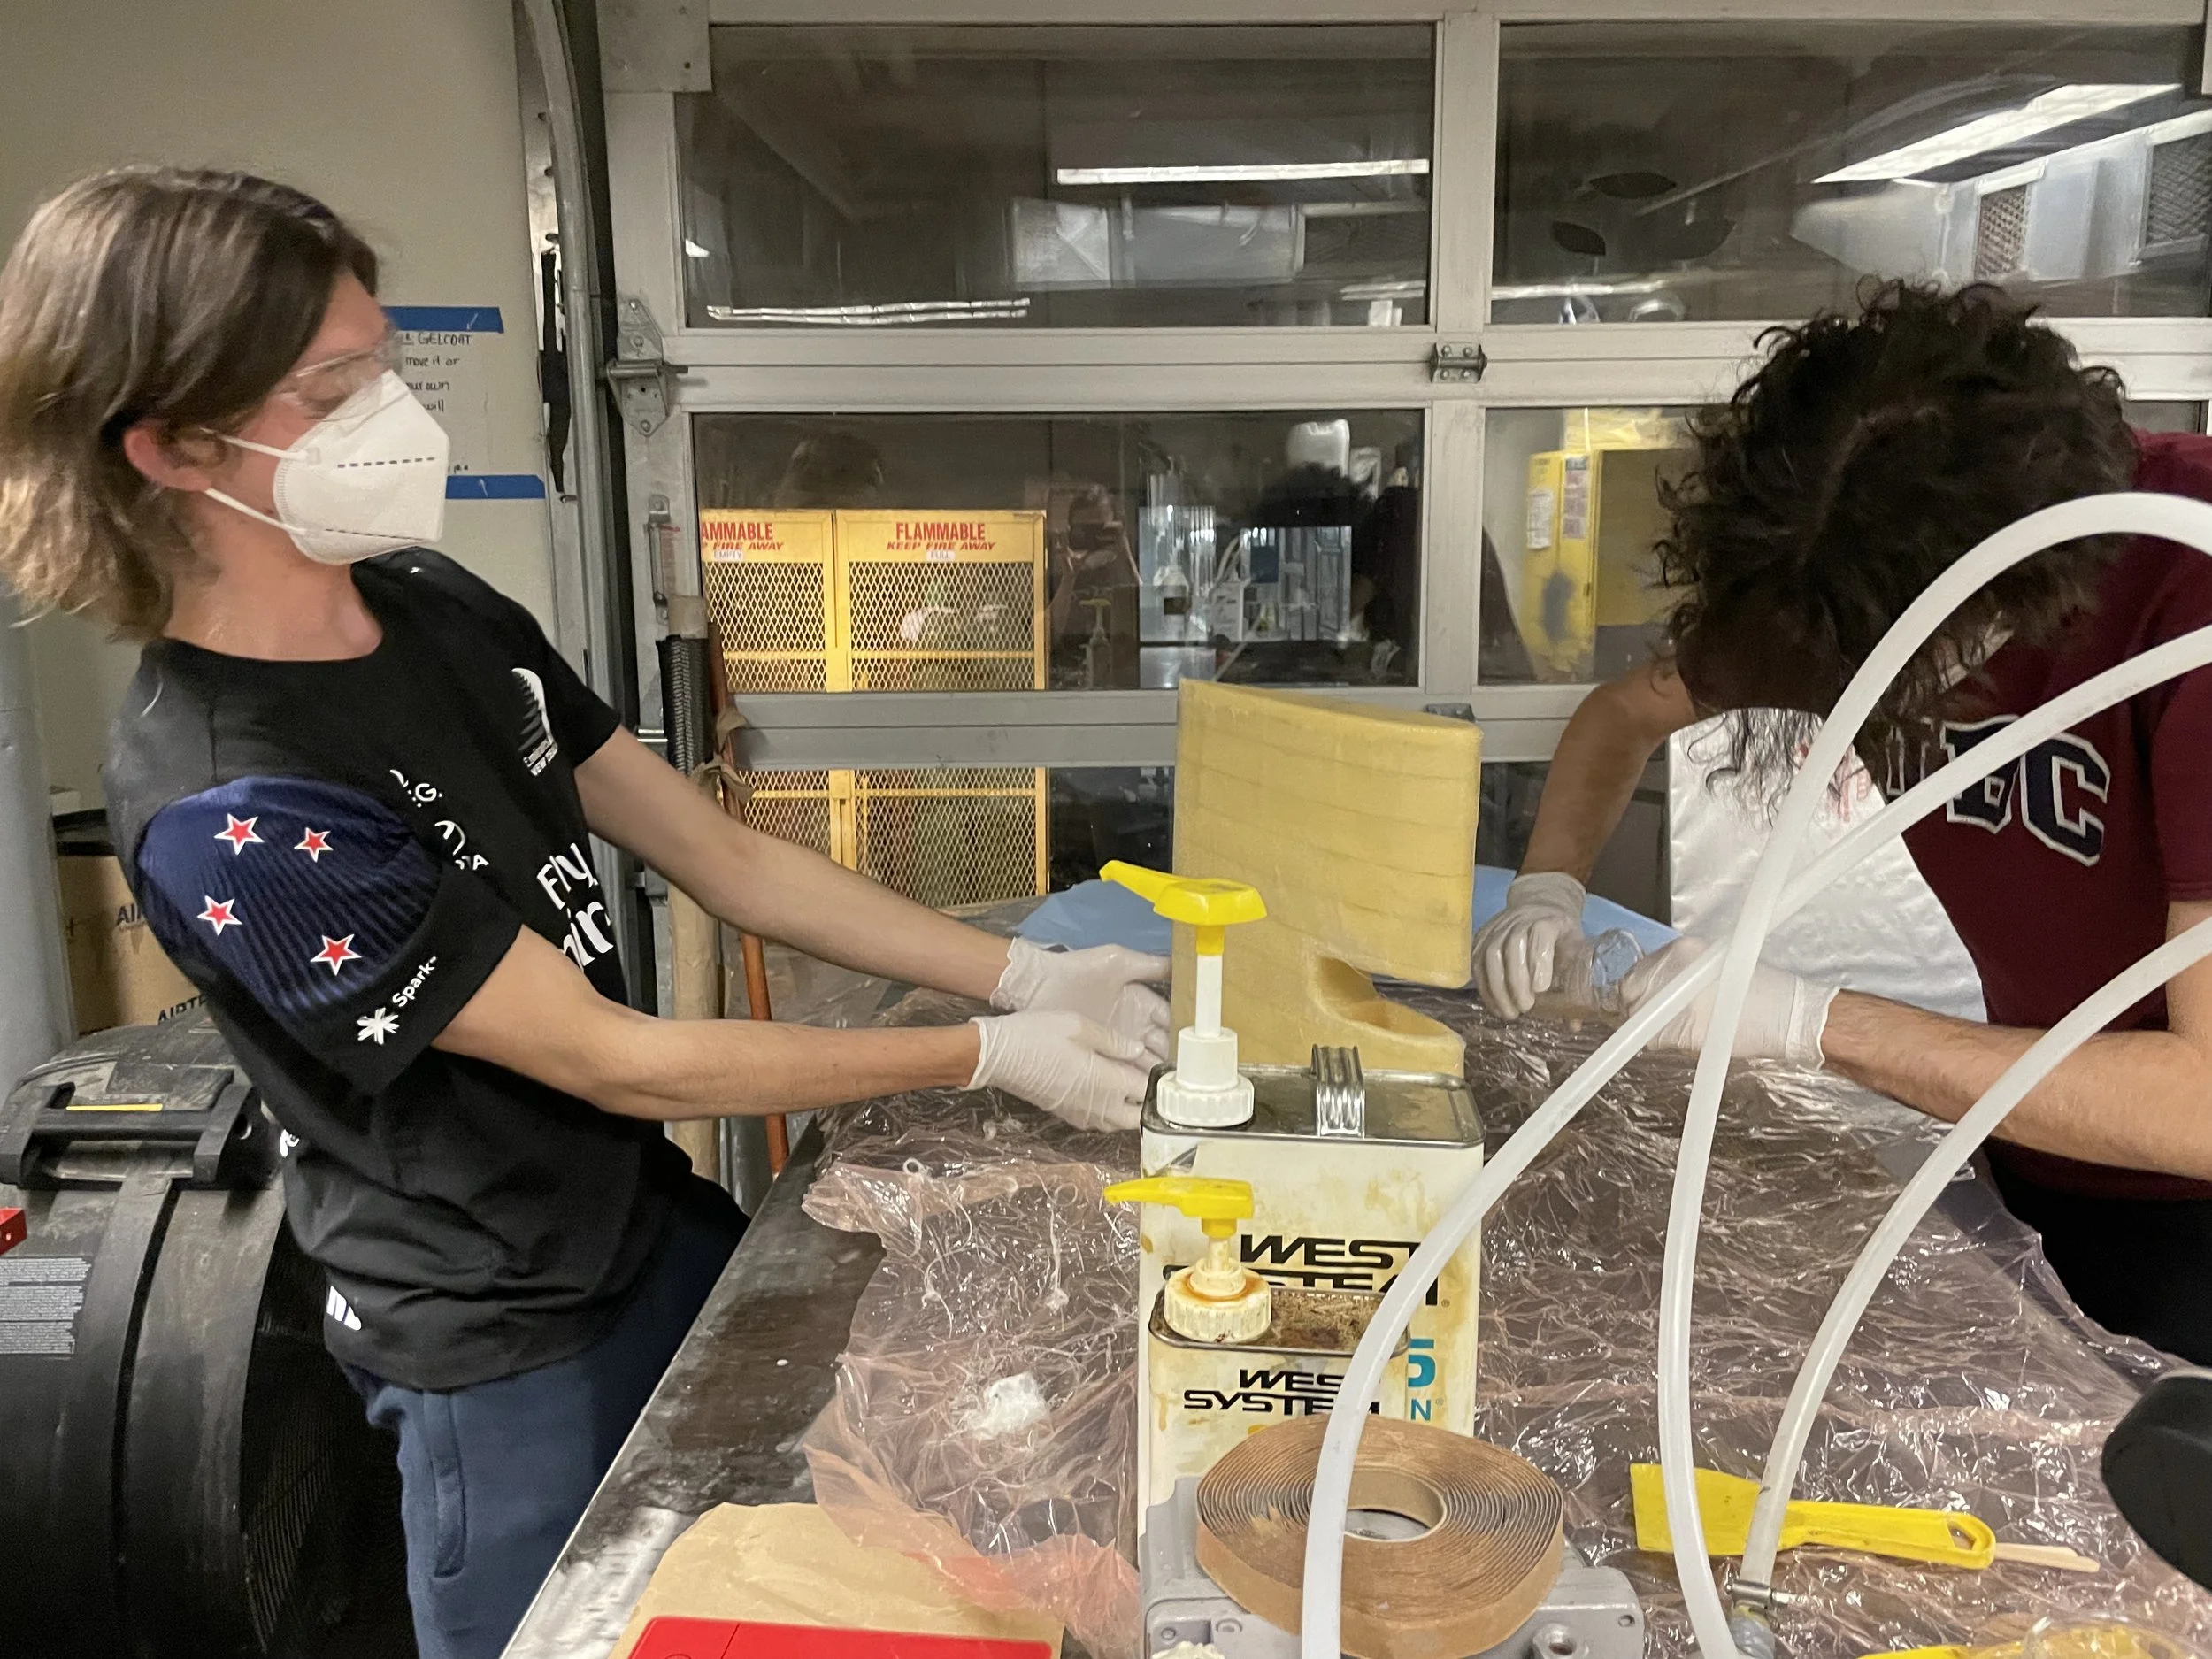
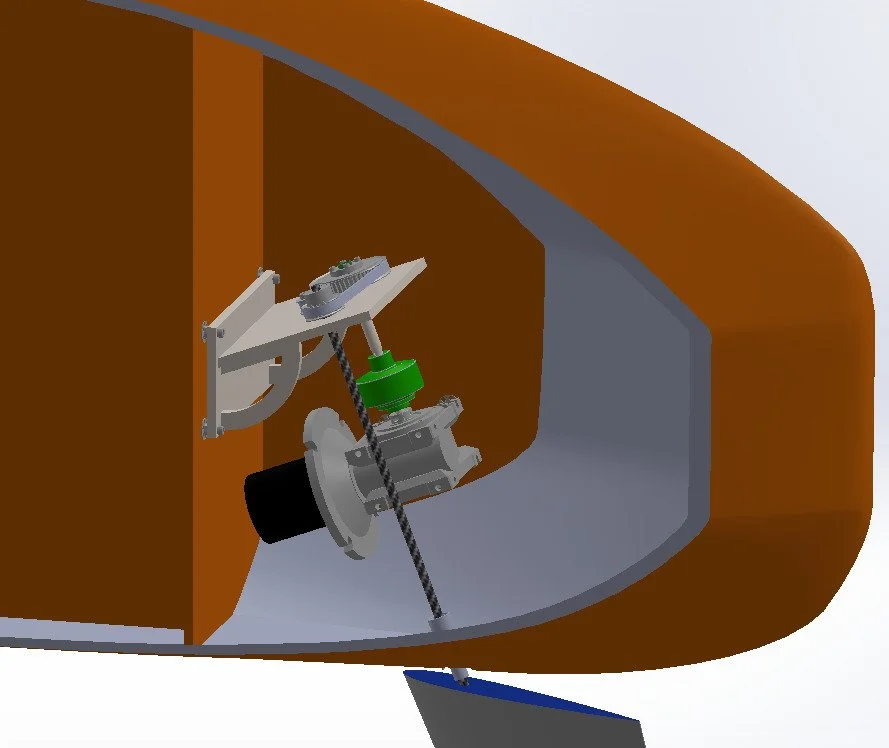
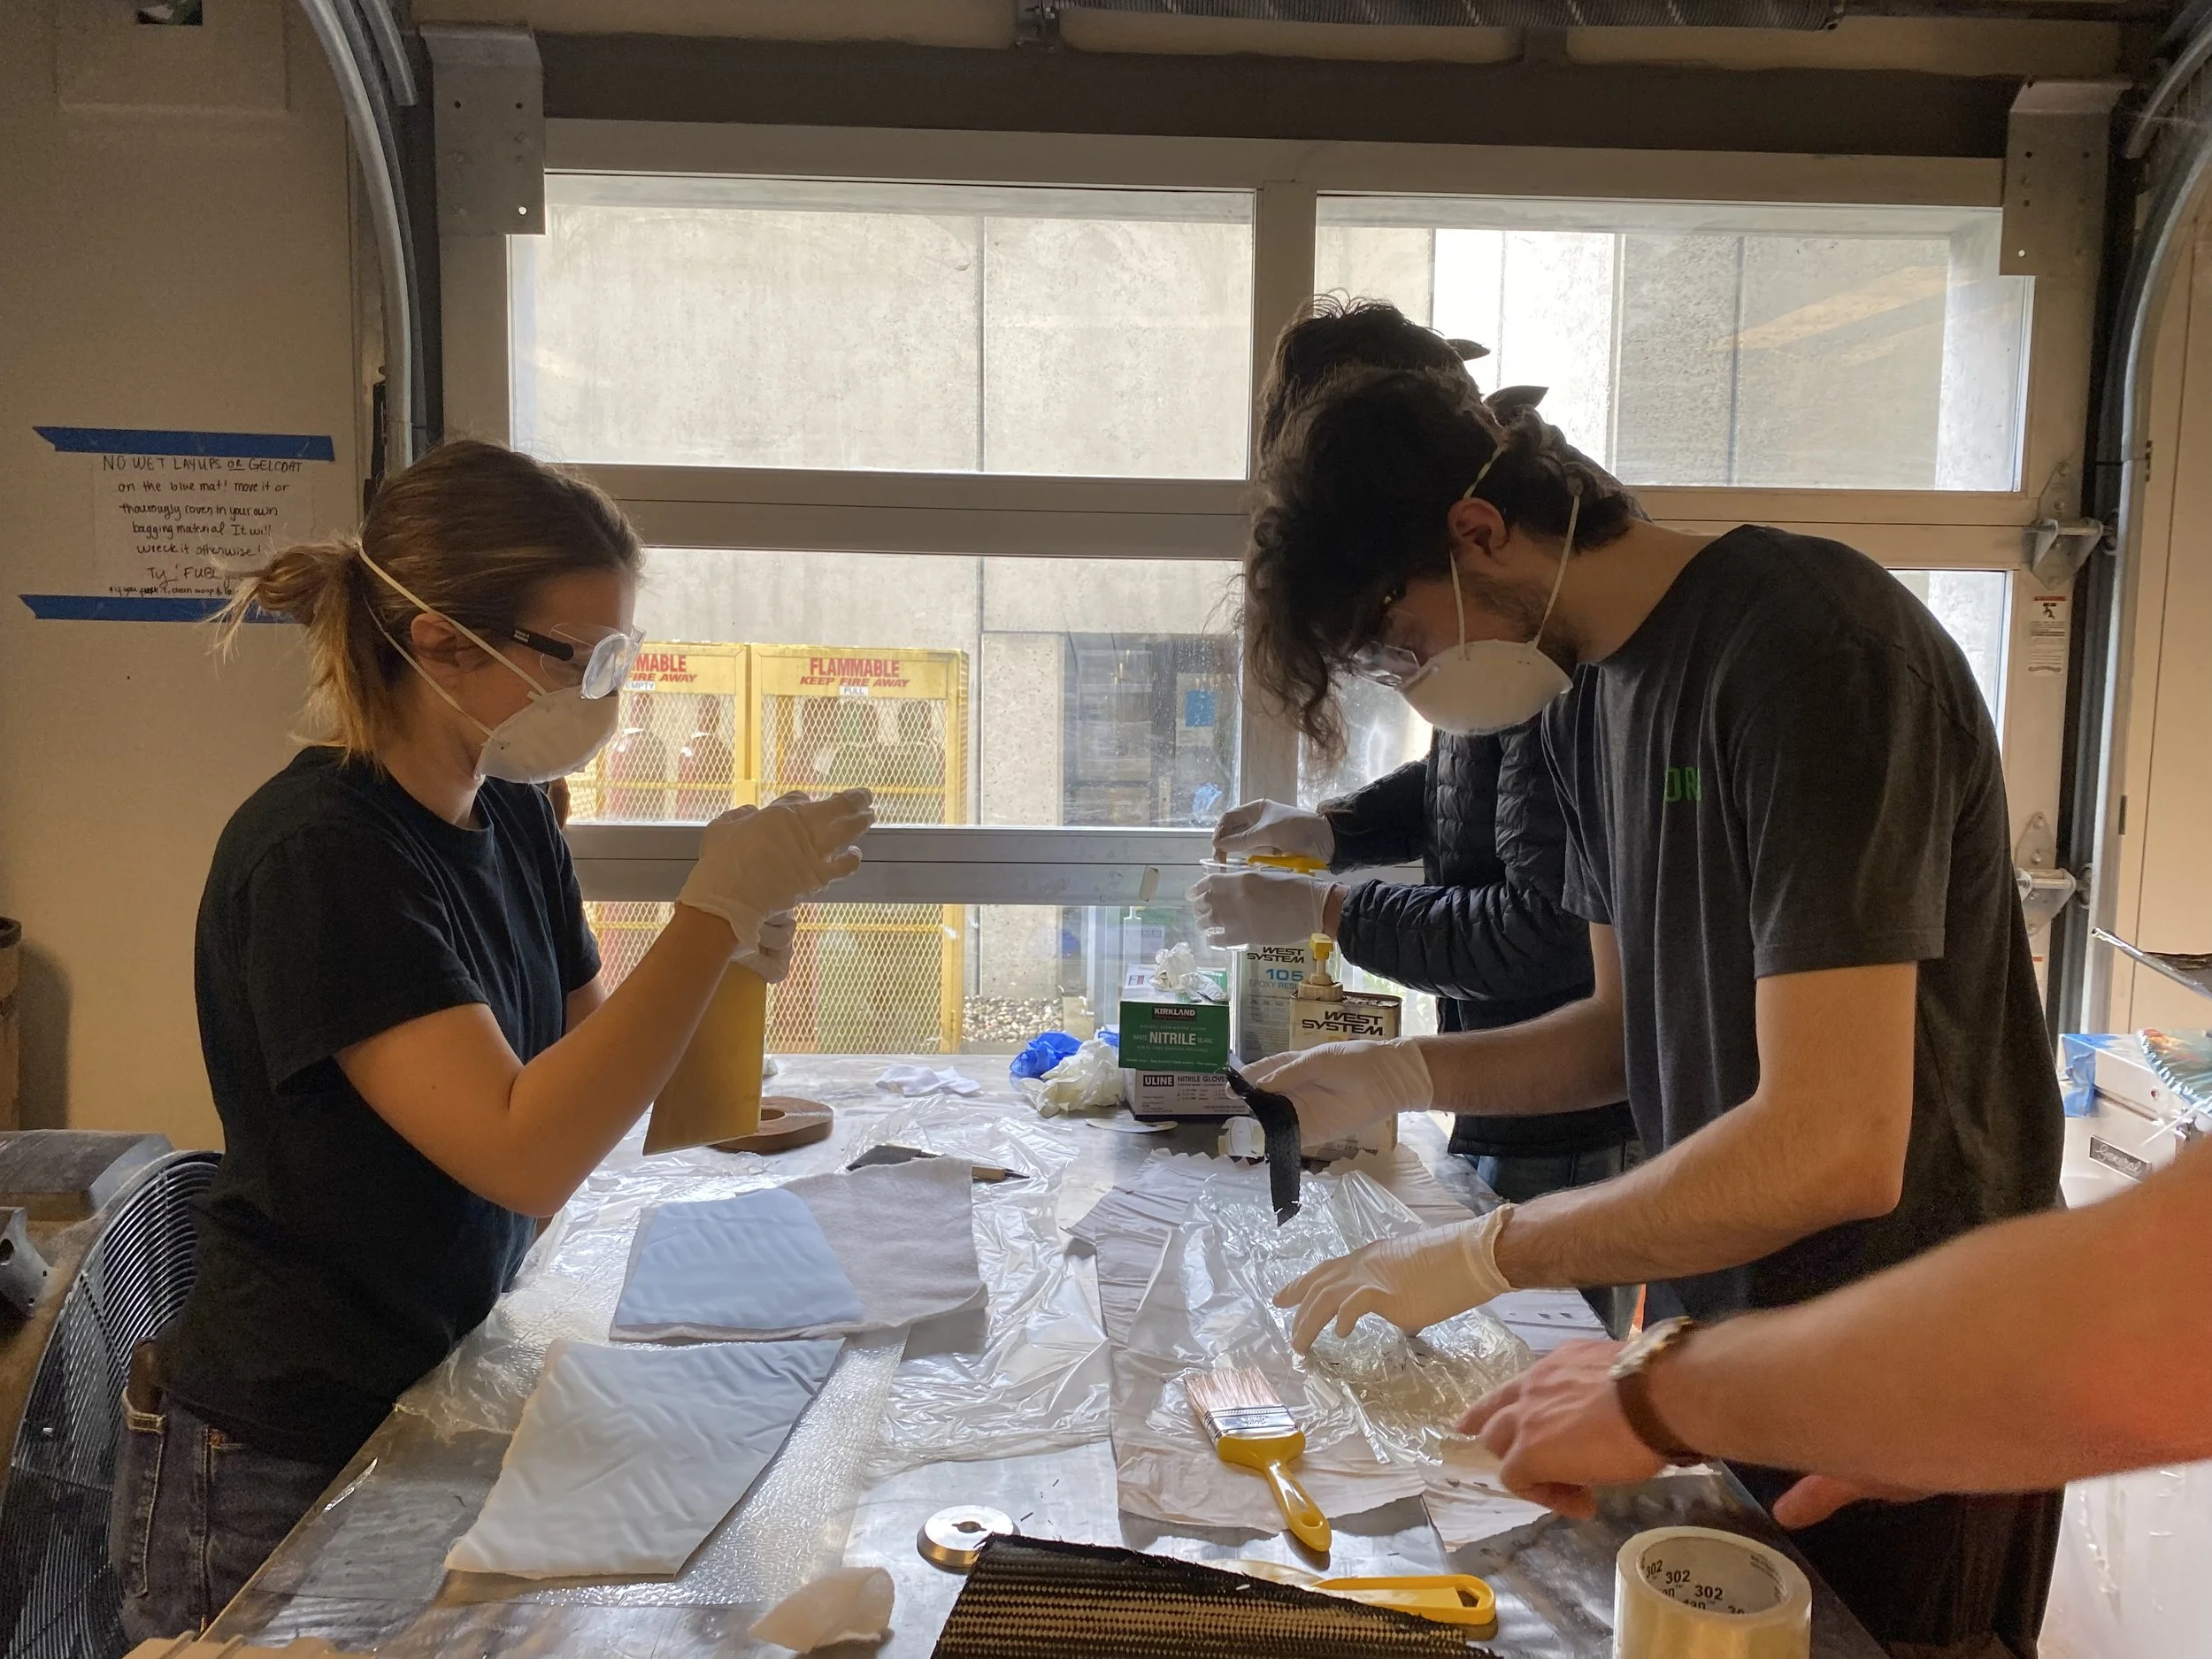
On the mechanical side, the team developed the FULL BOAT CAD MODEL, creating a complete digital representation that enabled accurate integration across all structural and functional components. Extensive DESIGN INTEGRATION AND STRUCTURAL ANALYSIS were carried out for key elements of the vessel, including the BULKHEADS, KEEL BULB, KEEL FIN, SAIL COMPONENTS, TRIM TAB ACTUATION, RIB STRUCTURE, SHELL, and RUDDER ACTUATION SYSTEM. These efforts ensured hydrodynamic performance and mechanical reliability. The team also took on PHYSICAL PROTOTYPING, enabling early validation of critical components.
In parallel, the electrical team worked on CONCEPT-LEVEL PROTOTYPES to explore various hardware configurations. This was complemented by ongoing FIRMWARE DEVELOPMENT, which began establishing the software required to interface with sensors, actuators, and communication systems.
On the software side, the team focused on building the foundational infrastructure for autonomous control. They developed an INTEGRATION TESTING FRAMEWORK, implemented CONTROLLERS FOR RUDDER AND SAIL ACTUATION, and created a CAN FRAME PARSER. Additionally, the team added a GLOBAL PATH TRACKING SYSTEM, laying the groundwork for autonomous navigation and long-range mission planning.